 Tel.:
 Sales@alphageo-info.com

GNSS Reference Receiver Solutions for Marine, UAV, Robotics, and Smart Transportation Projects
- Why GNSS Reference Receiver Architecture Defines Project Accuracy
- The Role of the Base Station in RTK and PPK Workflows
- Correction Data Formats and Communication Links
- Multipath Mitigation and Environmental Hardening
- Application-Specific Demands Across Marine, UAV, Robotics, and Smart Transportation
- Marine Hydrographic Surveying and Offshore Operations
- UAV Mapping and Precision Agriculture Payloads
- Autonomous Robotics and Industrial Automation
- Smart Transportation and V2X Infrastructure
- Key Technical Parameters: A Comparative Framework
- How alphageo Delivers on These Demands
- Fifteen Years of High-Precision GNSS Engineering
- A Complete Ecosystem for Every Application Domain
- Frequently Asked Questions
A GNSS reference receiver is the backbone of any high-precision positioning system. Whether I am deploying a hydrographic survey vessel in open water, calibrating a UAV mapping payload, integrating centimeter-level guidance into an autonomous robot, or building a smart transportation corridor, the quality and reliability of the reference station determines everything downstream. After more than fifteen years working alongside engineers, project managers, and procurement teams across these industries, I can say without hesitation that the single most common source of project failure is not the rover hardware or the software pipeline — it is an underspecified or poorly understood reference receiver architecture. In this article I walk through the real-world demands each application places on a GNSS reference receiver, the technical parameters that actually matter, and the solution framework I recommend to teams who need results they can stake their reputation on.
Why GNSS Reference Receiver Architecture Defines Project Accuracy
The Role of the Base Station in RTK and PPK Workflows
Every RTK (Real-Time Kinematic) or PPK (Post-Processed Kinematic) workflow depends on a known, stable reference point broadcasting correction data to one or more rovers. The reference receiver sits at that known point, continuously tracking signals from GPS, GLONASS, BeiDou, Galileo, and QZSS constellations simultaneously. When I first started deploying these systems in 2009, dual-frequency GPS-only receivers were the industry standard. Today, a project that does not leverage at least four constellations with dual or triple frequency tracking is leaving significant accuracy and availability on the table. According to the U.S. government's official GNSS resource portal, multi-constellation receivers can reduce positioning errors by up to 60% compared to single-constellation systems under challenging sky-view conditions — a figure I have personally validated on urban canyon mapping projects.
The reference receiver must also maintain an extremely stable antenna phase center. Any movement, even sub-millimeter thermal expansion of a poorly designed mount, propagates directly into rover position errors. I always specify a choke-ring or survey-grade pinwheel antenna paired with the reference receiver on permanent or semi-permanent installations. For temporary deployments — a common scenario in marine and UAV projects — I use a rapid-deployment tripod with forced-centering hardware and verify the setup with a redundant check-in point before any data collection begins.
Correction Data Formats and Communication Links
The reference receiver is only as useful as the correction stream it produces. RTCM 3.x has become the universal standard for broadcasting raw observations and computed corrections, and I strongly prefer it over proprietary formats because it ensures interoperability across rover brands and software platforms. For marine projects operating beyond radio range, I route RTCM streams over cellular LTE or satellite communication links. For UAV operations where latency must stay below 100 milliseconds to maintain centimeter-level RTK fix, I use a dedicated UHF radio link operating in the 400–900 MHz band. The RTCM Special Committee 104 continues to update these standards, and staying current with RTCM 3.3 MSM (Multiple Signal Messages) has been essential for supporting modern multi-constellation rovers in my recent smart transportation deployments.
Multipath Mitigation and Environmental Hardening
A reference receiver installed near reflective surfaces — a ship's superstructure, a warehouse roof, or a roadside gantry — will suffer multipath interference that corrupts the correction stream for every rover in the network. I mitigate this through careful site selection, antenna ground plane design, and signal processing algorithms that flag and down-weight multipath-affected observations. Modern receivers from reputable manufacturers implement carrier-smoothing and multipath detection internally, but I always validate performance with a 24-hour static sky plot before committing a site to production use. Environmental hardening is equally non-negotiable: IP67 or better ingress protection, an operating temperature range of at least -40°C to +75°C, and vibration resistance compliant with IEC 60068 environmental testing standards are the minimum specifications I accept for any field deployment.
Application-Specific Demands Across Marine, UAV, Robotics, and Smart Transportation
Marine Hydrographic Surveying and Offshore Operations
Marine environments are among the most demanding for any GNSS reference receiver setup. Salt spray, vessel motion, electromagnetic interference from navigation electronics, and the need to maintain a correction link over water — sometimes tens of kilometers from shore — all compound the challenge. In my hydrographic surveying projects, I typically establish a shore-based reference station with a high-gain antenna and a long-range radio or cellular modem, then verify the baseline integrity using independent tide gauge data. For offshore work beyond 20 kilometers, I integrate the reference receiver into a Continuously Operating Reference Station (CORS) network or use Precise Point Positioning (PPP) augmented by services like the Natural Resources Canada CSRS-PPP service to achieve sub-decimeter accuracy without a local base station. The combination of a robust reference receiver with a quality echo sounder and motion reference unit is what separates a defensible bathymetric dataset from one that will be rejected by a port authority or dredging contractor.
UAV Mapping and Precision Agriculture Payloads
UAV photogrammetry and LiDAR mapping have transformed how I deliver topographic and volumetric data to clients in construction, mining, and agriculture. The reference receiver in a UAV workflow serves a dual purpose: it provides the RTK correction stream that drives the drone's onboard GNSS module during flight, and it logs raw observations for PPK reprocessing as a quality assurance fallback. I have found that even with a solid RTK fix throughout a flight, running PPK reprocessing afterward and comparing the two solutions catches systematic errors that would otherwise go undetected. The reference receiver's logging rate matters here — I specify a minimum of 5 Hz raw observation logging, and for high-speed fixed-wing UAV operations I push that to 20 Hz to ensure sufficient temporal resolution for tight trajectory reconstruction.
Autonomous Robotics and Industrial Automation
Ground-based autonomous robots — whether agricultural, construction, or logistics platforms — rely on a GNSS reference receiver to anchor their localization stack. In robotics applications, I integrate the reference receiver output with an IMU and wheel odometry through an Extended Kalman Filter, which maintains centimeter-level positioning even during brief GNSS outages in warehouses or under tree canopy. The key reference receiver specification here is initialization time: a receiver that takes more than 30 seconds to achieve a fixed RTK solution after power-up creates unacceptable operational delays in a high-throughput autonomous system. I also pay close attention to the receiver's output capability — dual-antenna configurations that provide both position and from a single reference unit simplify the integration architecture considerably.
Smart Transportation and V2X Infrastructure
Smart transportation projects — including connected vehicle corridors, autonomous shuttle deployments, and high-definition map generation — demand a reference receiver network that delivers sub-10-centimeter accuracy at highway speeds with near-zero latency. I have designed CORS networks for smart highway projects where reference stations are spaced at 30–50 kilometer intervals, each feeding corrections into a network RTK engine that interpolates the optimal correction for any rover within the coverage area. The reference receivers in these networks must support continuous unattended operation, remote health monitoring, and automatic restart after power interruptions. Integration with a manufacturing monitoring system for real-time health telemetry — tracking signal quality, battery voltage, communication link status, and temperature — is something I now consider mandatory for any infrastructure-grade deployment.
Key Technical Parameters: A Comparative Framework
Over the years I have developed a standardized evaluation matrix for selecting a GNSS reference receiver for any of the four application domains discussed above. The table below summarizes the critical parameters and how requirements differ across use cases.
| Parameter | Marine Hydrographic | UAV Mapping | Autonomous Robotics | Smart Transportation |
|---|---|---|---|---|
| Constellation Support | GPS+GLONASS+BeiDou+Galileo | GPS+GLONASS+BeiDou+Galileo | GPS+GLONASS minimum | GPS+GLONASS+BeiDou+Galileo |
| Frequency Bands | Triple-frequency (L1/L2/L5) | Dual or Triple-frequency | Dual-frequency (L1/L2) | Triple-frequency (L1/L2/L5) |
| RTK Horizontal Accuracy | 8 mm + 1 ppm | 10 mm + 1 ppm | 10 mm + 1 ppm | 8 mm + 0.5 ppm |
| Raw Data Logging Rate | 1–5 Hz | 5–20 Hz | 5–10 Hz | 1–5 Hz |
| Communication Interface | UHF Radio + LTE + Serial | UHF Radio + Wi-Fi | UHF Radio + CAN Bus | LTE + Ethernet + RS-232 |
| Ingress Protection | IP67 minimum | IP54 minimum | IP65 minimum | IP67 minimum |
| Operating Temperature | -40°C to +75°C | -20°C to +60°C | -30°C to +65°C | -40°C to +75°C |
| Unattended Operation | Required | Not required | Preferred | Required |
| Initialization Time (RTK Fix) | <60 seconds | <30 seconds | <30 seconds | <60 seconds |
This matrix has saved me countless hours of post-project troubleshooting. When a client comes to me with a vague requirement like we need centimeter accuracy, I use this framework to translate that into a concrete specification that procurement teams can evaluate objectively. The IEEE Intelligent Transportation Systems Society has published extensive guidelines on GNSS performance requirements for connected and automated mobility applications that I reference when designing smart transportation reference networks.
How alphageo Delivers on These Demands
Fifteen Years of High-Precision GNSS Engineering
When I evaluate a GNSS reference receiver supplier for a demanding project, I look for three things above all else: depth of engineering experience, breadth of the product ecosystem, and a track record of quality certification. alphageo, founded in 2008, checks all three boxes in a way that very few manufacturers can match. With over fifteen years of focused development in high-precision GNSS technology, alphageo has built a product line that covers the full positioning workflow — from the reference station itself through to the rover, the data link, and the processing software. That end-to-end ownership of the signal chain is something I value enormously because it eliminates the finger-pointing between vendors that plagues multi-supplier integrations.
Every alphageo product undergoes strict quality control and has passed certification from international authoritative bodies, which means when I specify an alphageo GNSS Receiver for a marine or smart transportation project, I am not taking a risk on an uncertified component. The company's philosophy — that quality, performance, and reliability make a difference — aligns exactly with what I tell my own clients: the cost of a positioning failure in a hydrographic survey or an autonomous vehicle corridor is orders of magnitude greater than the cost difference between a High Quality receiver and a budget alternative.
A Complete Ecosystem for Every Application Domain
What sets alphageo apart in my experience is the coherence of its product ecosystem. For marine hydrographic surveying, the combination of alphageo's GNSS Receiver with its dedicated Hydro Survey and Hydrographic Surveying equipment means I can build a fully integrated, single-vendor solution that is validated to work together. The Lidar Scanner products extend that capability into above-water topographic capture, enabling seamless land-to-water surveys that are increasingly demanded by coastal engineering and flood modeling clients. For UAV and robotics applications, the compact, lightweight GNSS Receiver modules integrate cleanly with standard autopilot architectures, and the Data Controller hardware provides the rugged field computing platform needed to manage correction streams and log raw observations simultaneously.
For smart transportation and infrastructure monitoring, alphageo's Monitoring System and Radios products complete the reference station package. The radio solutions cover the UHF bands I rely on for low-latency RTK correction broadcasting, and the monitoring system hardware provides the remote health telemetry that infrastructure-grade deployments require. Rounding out the portfolio, the Geophysical Equipments line serves clients in subsurface investigation and utility mapping — a natural complement to GNSS-based surface positioning in construction and civil engineering projects. The fact that alphageo operates its own R&D and manufacturing facilities means lead times are predictable and customization requests — antenna connector types, firmware feature additions, OEM integration — are handled by engineers who actually built the product, not by a sales team relaying messages to a distant factory.
Frequently Asked Questions
What is a GNSS reference receiver and why does it matter for RTK projects?
A GNSS reference receiver is a fixed base station that continuously tracks satellite signals from multiple constellations and broadcasts correction data to rover units. In RTK workflows, the quality of the reference receiver directly determines the accuracy of every rover in the network. A poorly specified or poorly installed reference receiver introduces systematic errors that no amount of rover-side processing can correct.
How far can a GNSS reference receiver broadcast RTK corrections?
With a standard UHF radio link operating in the 400–900 MHz band, a reference receiver can typically broadcast corrections over 10–30 kilometers in open terrain. For marine or smart transportation projects requiring longer ranges, cellular LTE modems or satellite communication links can extend coverage indefinitely, though latency management becomes critical for real-time RTK applications.
What is the difference between RTK and PPK when using a GNSS reference receiver?
RTK (Real-Time Kinematic) uses the reference receiver's correction stream in real time, delivering centimeter-level positions to the rover during data collection. PPK (Post-Processed Kinematic) logs raw observations at both the reference receiver and the rover, then processes them together in office software after the mission. PPK is more resilient to communication link dropouts and is widely used as a quality assurance fallback in UAV mapping workflows.
Which GNSS constellations should a reference receiver support for marine and smart transportation use?
For marine hydrographic surveying and smart transportation infrastructure, I recommend a reference receiver that tracks at least four constellations: GPS, GLONASS, BeiDou, and Galileo, ideally on triple frequencies (L1, L2, and L5). Multi-constellation, multi-frequency tracking significantly improves availability, reduces initialization time, and enhances accuracy under challenging sky-view conditions such as coastal cliffs or urban canyons.
What ingress protection rating do I need for a marine GNSS reference receiver?
For marine deployments, a minimum of IP67 ingress protection is required, meaning the receiver can withstand temporary immersion in water up to one meter for 30 minutes. In offshore or splash-zone installations, I recommend IP68-rated enclosures or additional weatherproof housing. Salt spray resistance and corrosion-resistant connector materials are equally important specifications to verify before purchasing.
How does alphageo support GNSS reference receiver integration for UAV and robotics projects?
alphageo offers a complete ecosystem that includes compact GNSS Receiver modules optimized for UAV and robotics integration, UHF Radios for low-latency RTK correction links, and rugged Data Controller hardware for field computing. All products are manufactured under strict quality control and certified by international bodies, ensuring reliable interoperability across the full positioning workflow from reference station to rover.
Can a single GNSS reference receiver serve multiple rovers simultaneously?
Yes. A single reference receiver broadcasting RTCM 3.x corrections over a radio or network link can serve an unlimited number of rovers within its coverage range simultaneously, since the correction stream is a one-way broadcast. For network RTK deployments covering large areas — such as smart transportation corridors — multiple reference receivers feed into a network RTK engine that interpolates optimized corrections for any rover location within the network.

Though standard laser measurement solved part of the problem, we weren't satisfied. That's why we created the Matrix DM. Featuring two lasers for two distinct scenarios, it is designed to make laser measurement more direct than ever before.

MATRIX X is an innovative laser GNSS receiver with an adjustable laser module offering a 75°tilt range, supporting AR stakeout, 1408-channel high-stability GNSS, 120° calibration-free IMU and 32GB cyclic storage. It simplifies fieldwork and delivers faster, more reliable measurement in complex environments.
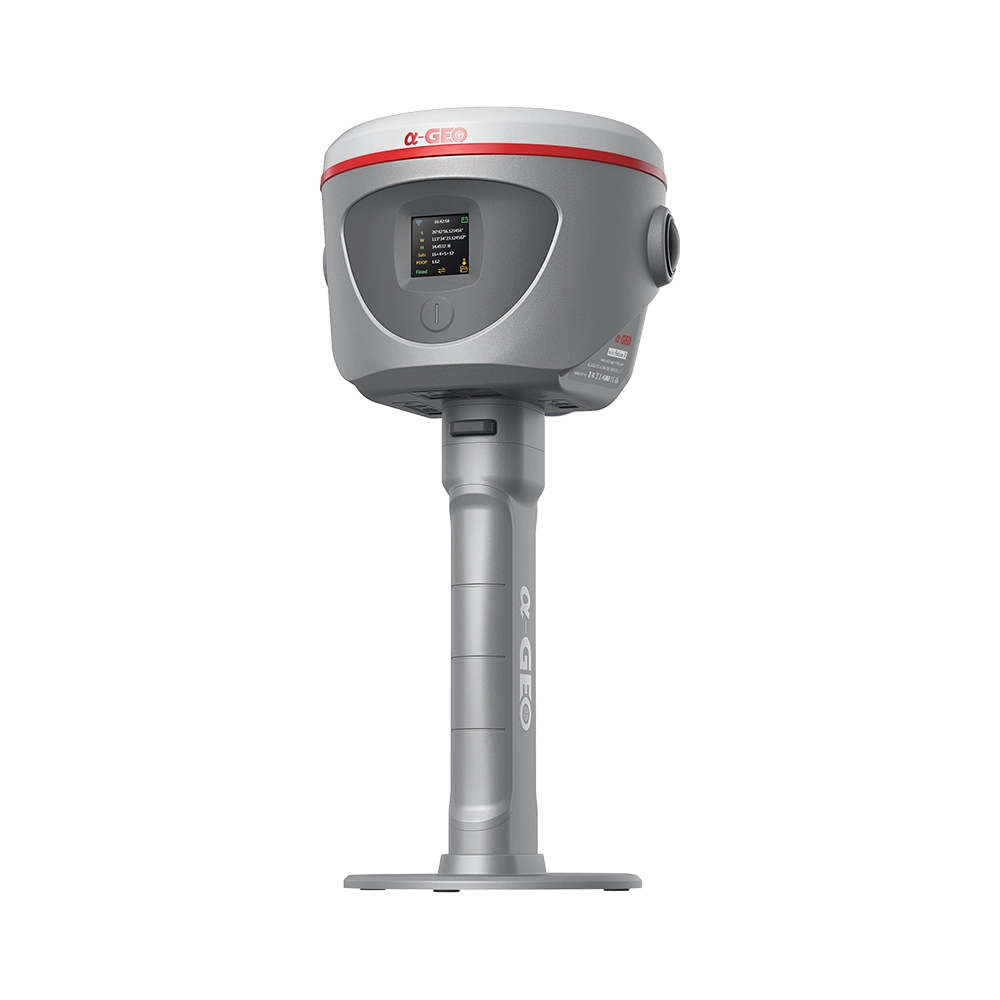
ALPHA GEO proudly presents the Falcon X-a groundbreaking surveying mobile terminal that integrates GNSS, high-precision vision modules, and LiDAR systems to redefine traditional RTK workflows. By combining SLAM technology with high-accuracy RTK and a powerful core processor, it delivers real-time point cloud coordinate calculations and establishes a unified coordinate system across both indoor and outdoor environments. With no need for post-processing, the data is immediately ready for engineering design, greatly improving efficiency and precision.
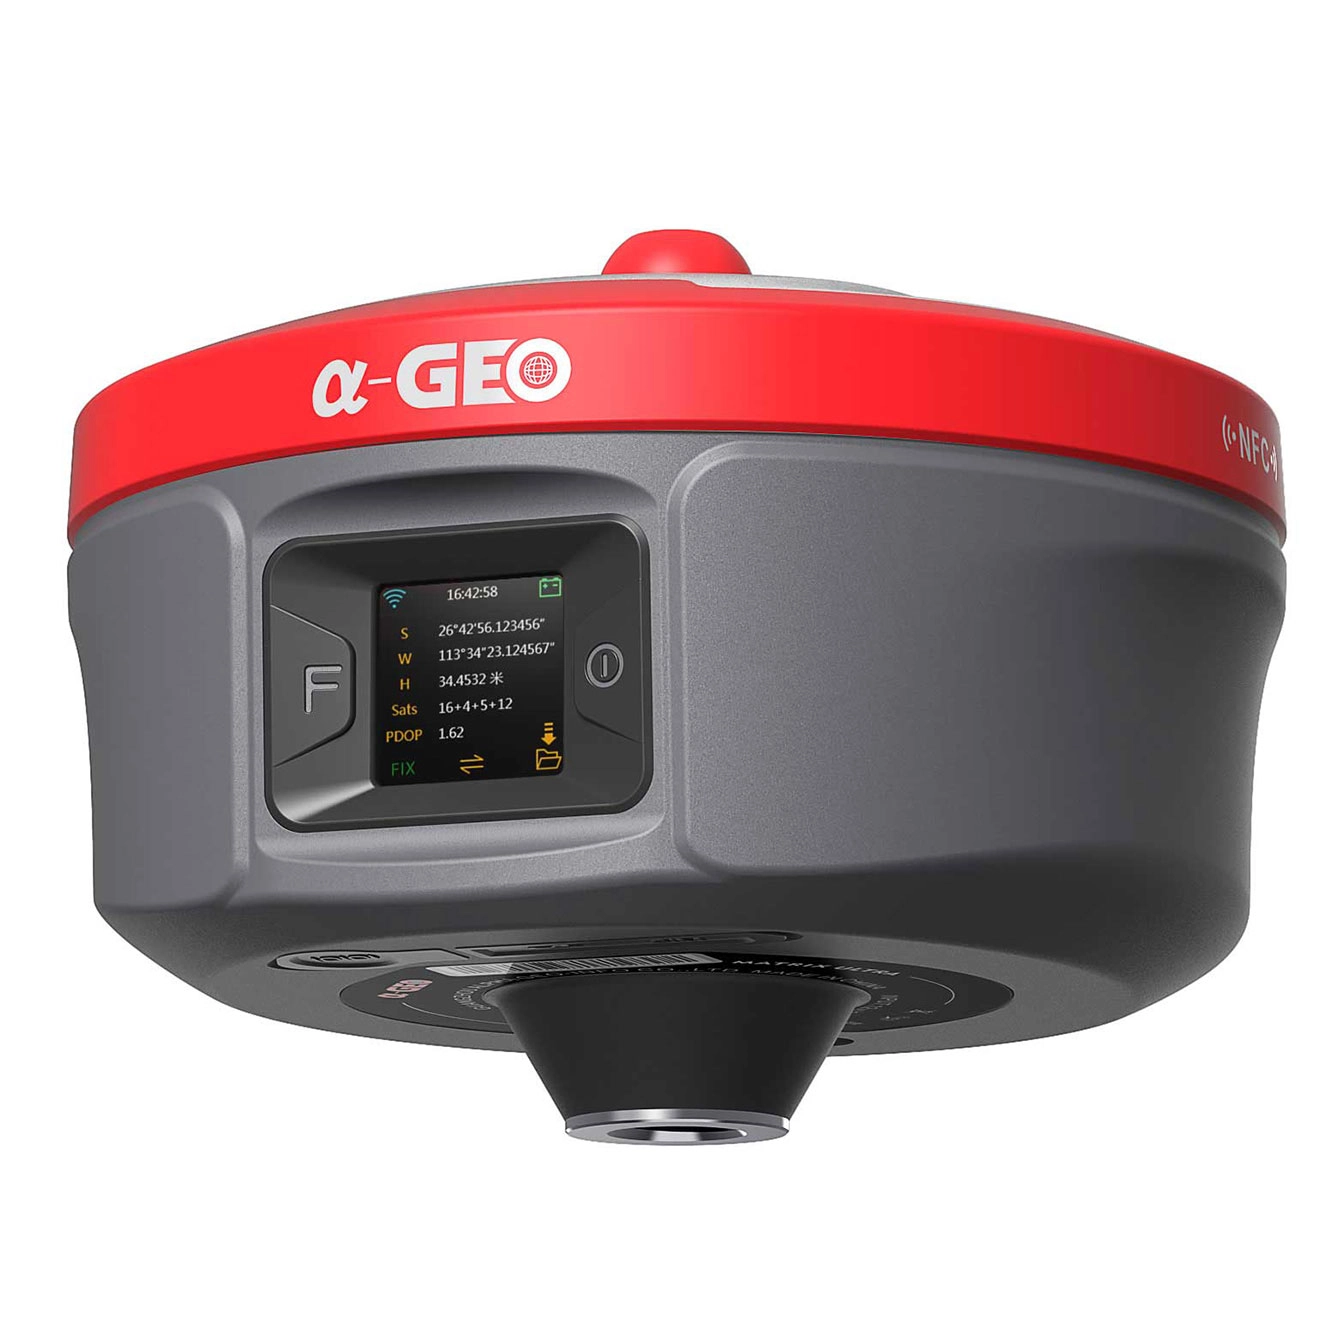
α-GEO, founded in 2008, is a global market-leading high-tech company focusing on high-precision GNSS technology.
alphageognss
alphageo
alphageoinfo